CONECT Project
Robotic Needle Insertion Guided by Real-time FEM Simulation
My PhD project at ICube (University of Strasbourg): robotic insertion of flexible needles in deformable tissue using inverse real-time finite element simulation, and augmented reality for surgery.
Project Overview
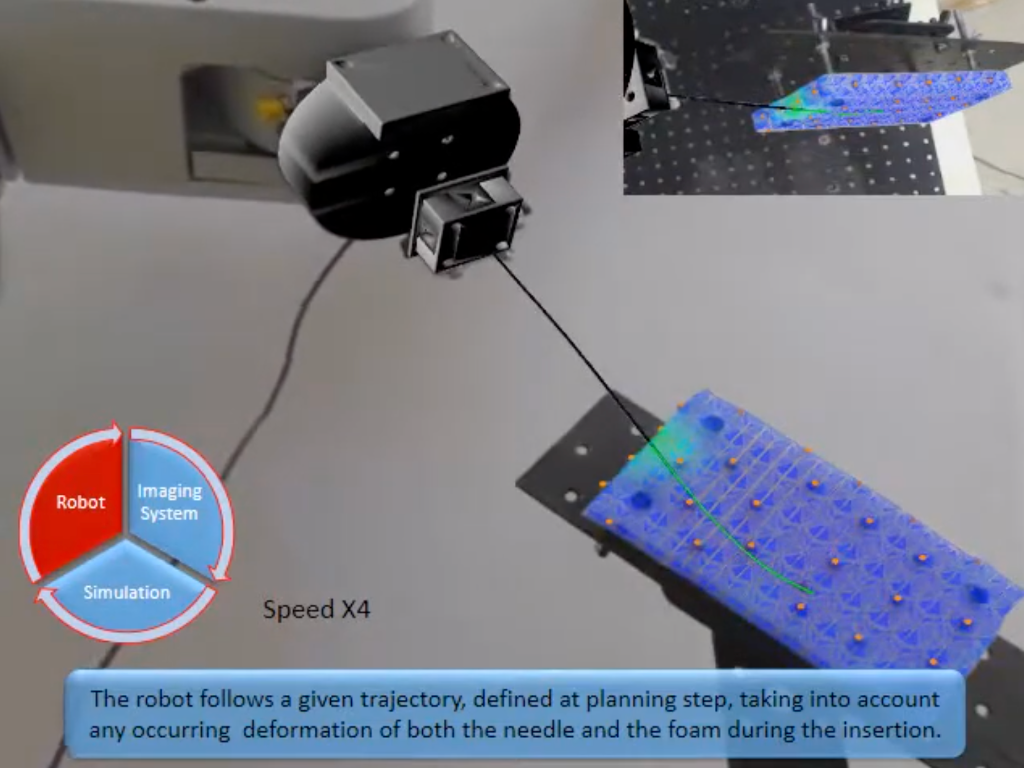
CONECT — Couplage de la rObotique et de la simulatioN médicalE pour des proCédures automaTisées — was my PhD project (2015–2018) at the ICube laboratory, University of Strasbourg, supervised by Dr. Hadrien Courtecuisse and Prof. Michel de Mathelin.
The goal was to control a robot inserting a flexible needle into deformable tissue. Both the needle and the tissue deform during insertion, so the target moves. A real-time finite element simulation, solved as an inverse problem, computes at each step the robot motion that keeps the needle on its planned trajectory.
Inverse FEM Simulation
Real-time finite element models of needle and tissue, inverted to compute robot commands.
Robotic Needle Insertion
Constraint-based needle–tissue interaction, with corrective and predictive steps during insertion.
Augmented Reality
Registration of deformable organ models for surgical AR, applied to open liver surgery.
Publications
- Robotic Insertion of Flexible Needle in Deformable Structures Using Inverse Finite-Element Simulation (2019) — Yinoussa Adagolodjo, Laurent Goffin, Michel de Mathelin, Hadrien Courtecuisse. IEEE Transactions on Robotics. HAL · DOI
- Couplage de la rObotique et de la simulatioN médicalE pour des proCédures automaTisées (CONECT) (2018) — Yinoussa Adagolodjo. PhD Thesis — Université de Strasbourg. HAL
- Marker-based Registration for Large Deformations – Application to Open Liver Surgery (2018) — Yinoussa Adagolodjo, Nicolas Golse, Eric Vibert, Michel de Mathelin, Stéphane Cotin, Hadrien Courtecuisse. ICRA 2018 – IEEE International Conference on Robotics and Automation. HAL · DOI
- Silhouette-based Pose Estimation for Deformable Organs – Application to Surgical Augmented Reality (2017) — Yinoussa Adagolodjo, Raffaella Trivisonne, Nazim Haouchine, Stéphane Cotin, Hadrien Courtecuisse. IROS 2017 – IEEE/RSJ International Conference on Intelligent Robots and Systems. HAL · DOI
- Inverse real-time Finite Element simulation for robotic control of flexible needle insertion in deformable tissues (2016) — Yinoussa Adagolodjo, Laurent Goffin, Michel de Mathelin, Hadrien Courtecuisse. IROS 2016 – IEEE/RSJ International Conference on Intelligent Robots and Systems. HAL · DOI
- Domain Decomposition for real time Simulation of needle insertion (2015) — Yinoussa Adagolodjo, Hadrien Courtecuisse, Raffaella Trivisonne, Laurent Goffin, Stéphane P.-A. Bordas, Michel de Mathelin. DD23 – International Conference on Domain Decomposition Methods. HAL
Contact me for more information about this work.