Research Projects
Current Research Projects
 Active
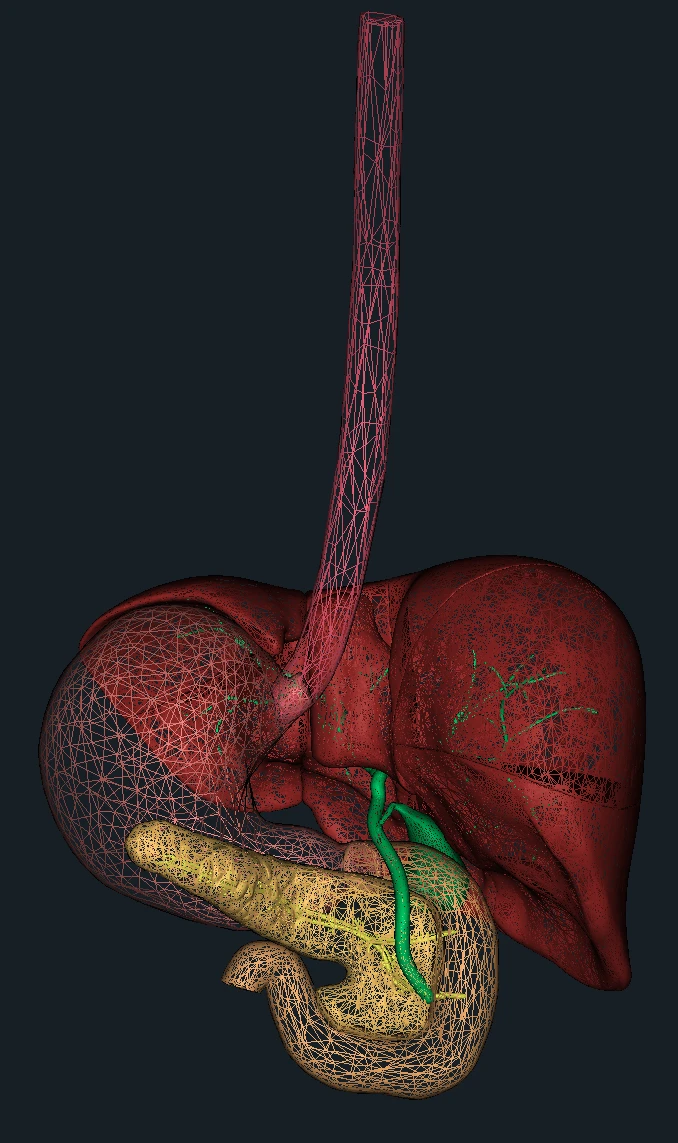
ADAGIO Project
Continuum Robots for Endoscopic Gallbladder Drainage
National project on tendon-actuated continuum robots for the endoscopic drainage of the gallbladder in acute cholecystitis.
 Active
IRE Project
Intelligent Robotic Endoscopes
European project on intelligent soft robotic endoscopes for minimally invasive surgery, combining real-time simulation, augmented reality guidance, computer vision and machine learning.
 Active
 Prostate Phantom
Multi-Chamber Pneumatically Actuated Prostate Phantom for Medical Training & Validation
Development of a pneumatically actuated prostate phantom with multiple independently controlled chambers for realistic simulation-based medical training and robotic system validation.
 Active
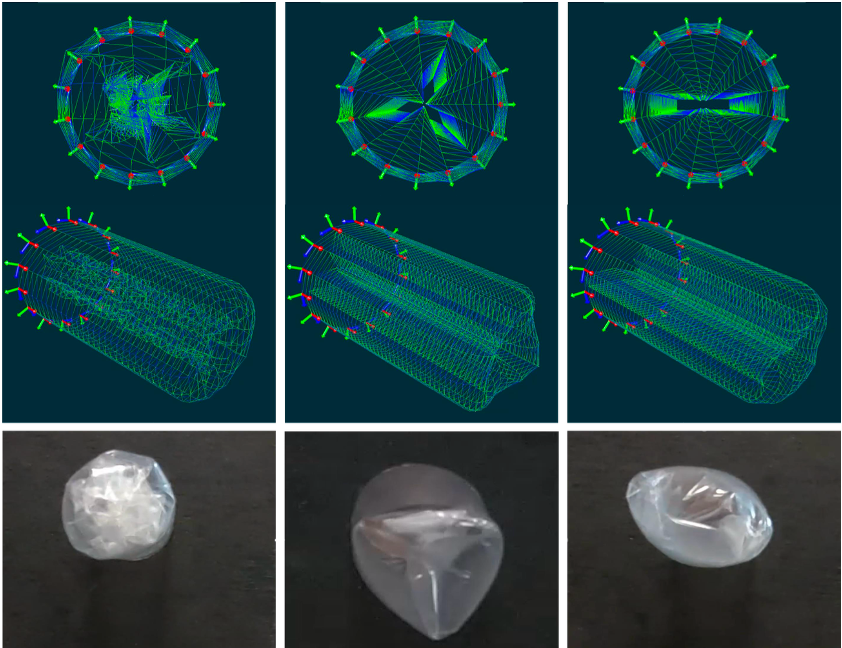
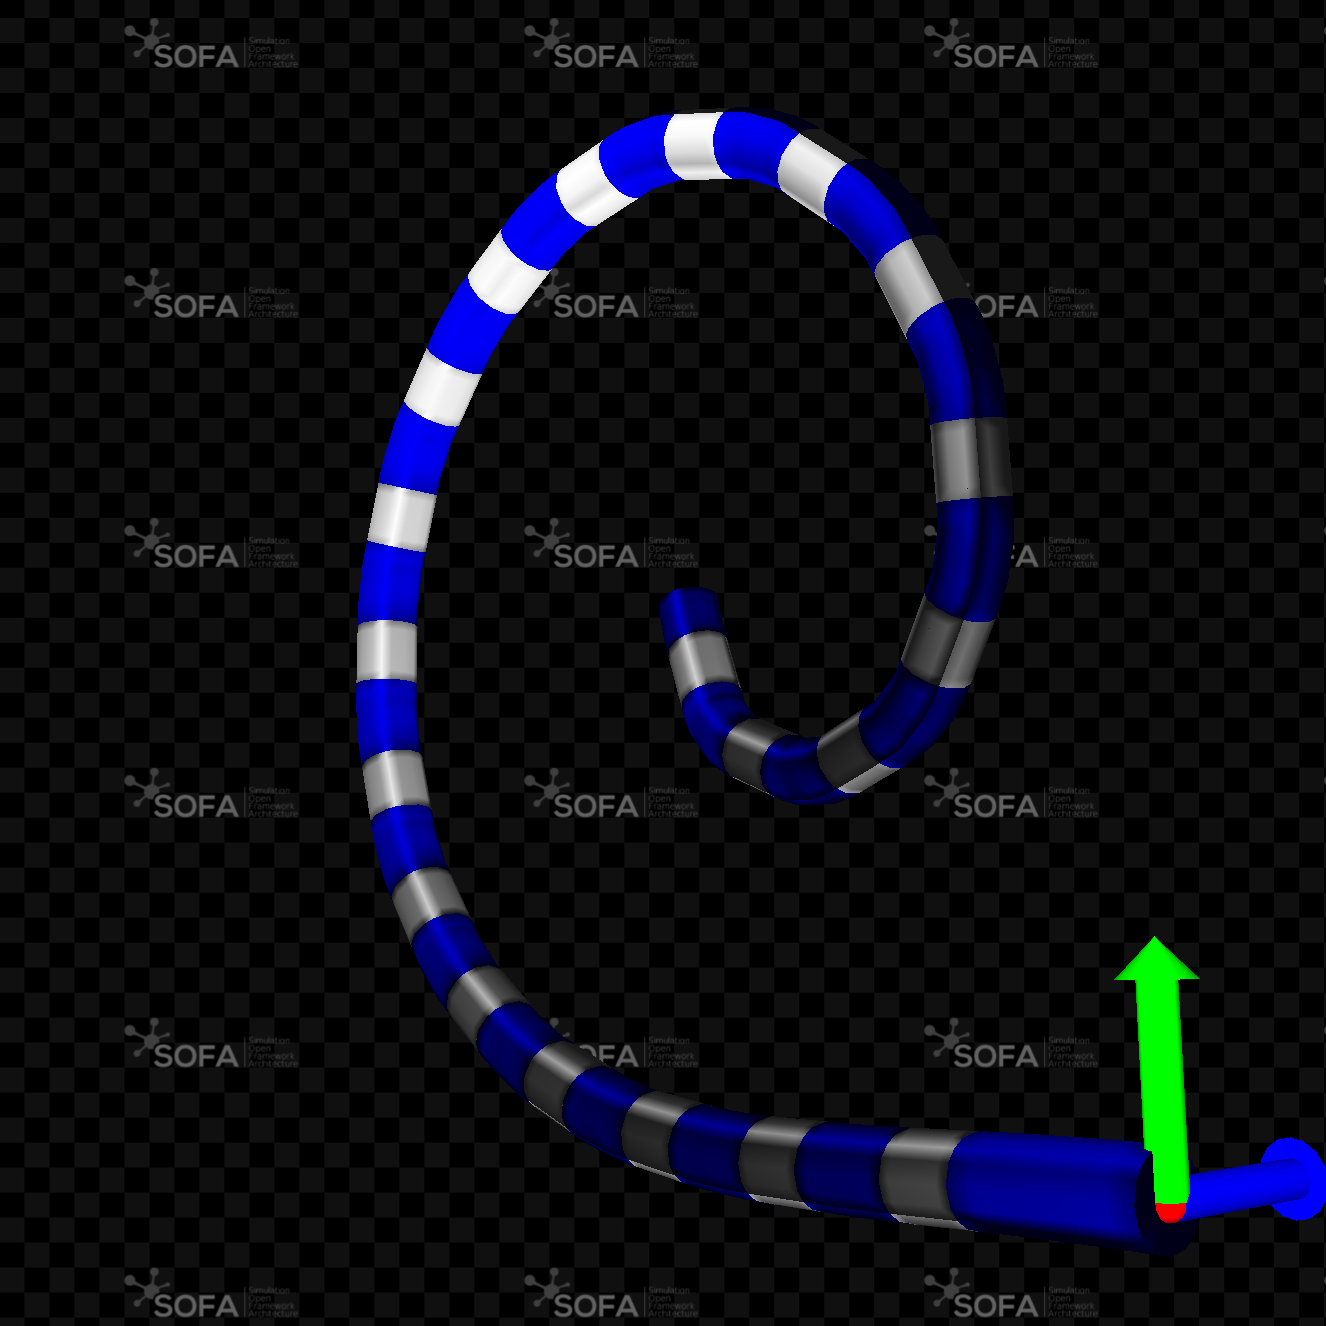
Growing Robot
Vine-Inspired Soft Robot for Endoscopic and Cardiovascular Procedures
Development of innovative vine-inspired growing robots using eversion principles for endoscopic and cardiovascular medical applications, including TAVI procedures and minimally invasive interventions.
 Active
ROBOCOP / ACCESS
Robotic Cochlear Implant Insertion and Patient-Specific Digital Twin
Robotization of cochlear implant insertion (ROBOCOP, 2019–2023), continued by ACCESS (2024–2029): a patient-specific digital twin for cochlear implant surgery.
 Active
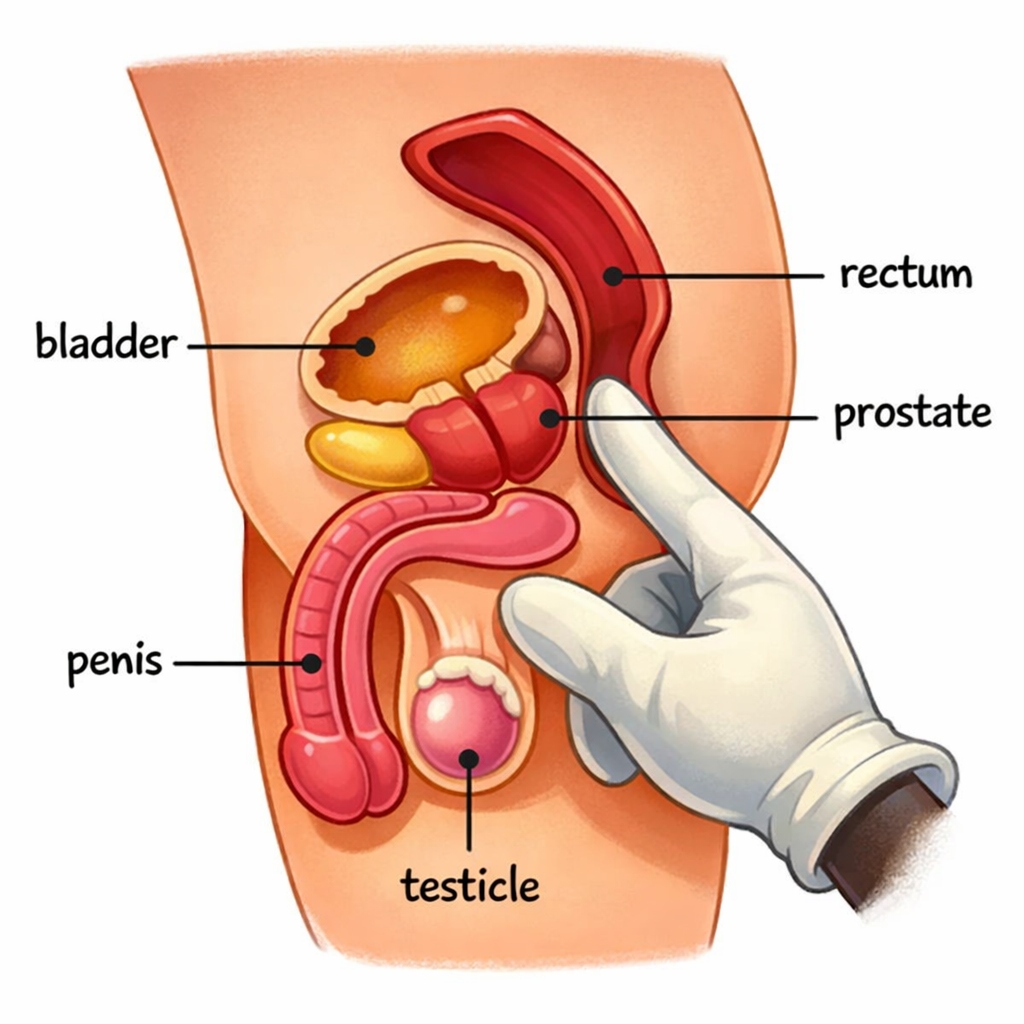
Prostate Biopsy Project
AI & Robotic Assistance for Prostate Cancer Diagnosis
Combining AI-based image analysis and robotics to improve prostate cancer diagnosis and targeted biopsies.
 Completed
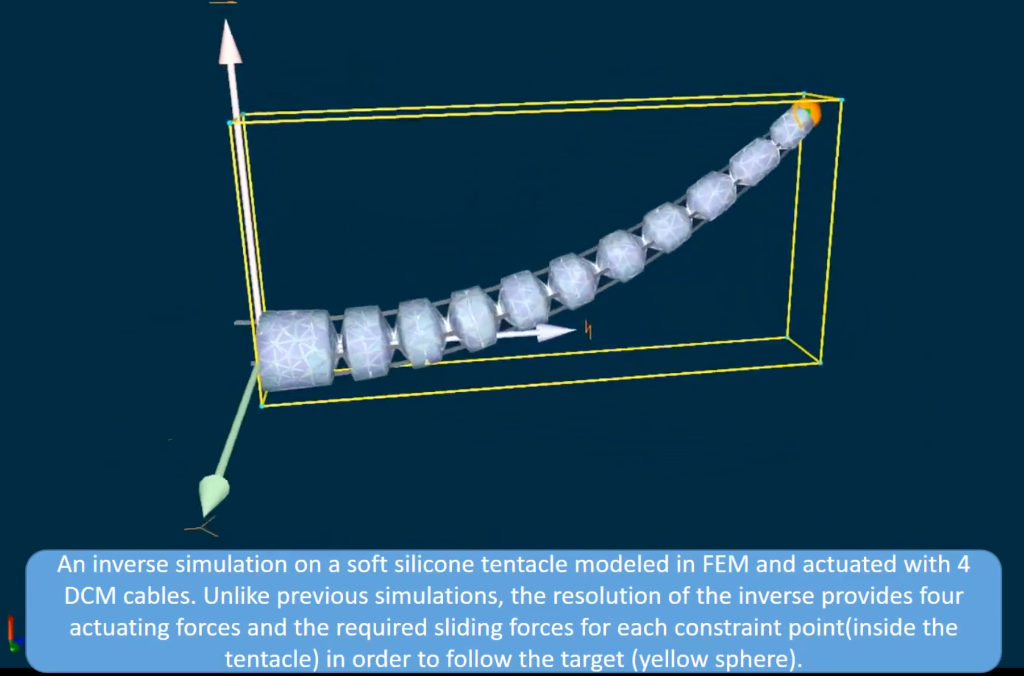
COSSEROOTS Project
Cosserat Theory for Soft Robotics Control
Research project applying Cosserat rod theory to the modeling and control of slender, continuum soft robots.
 Completed
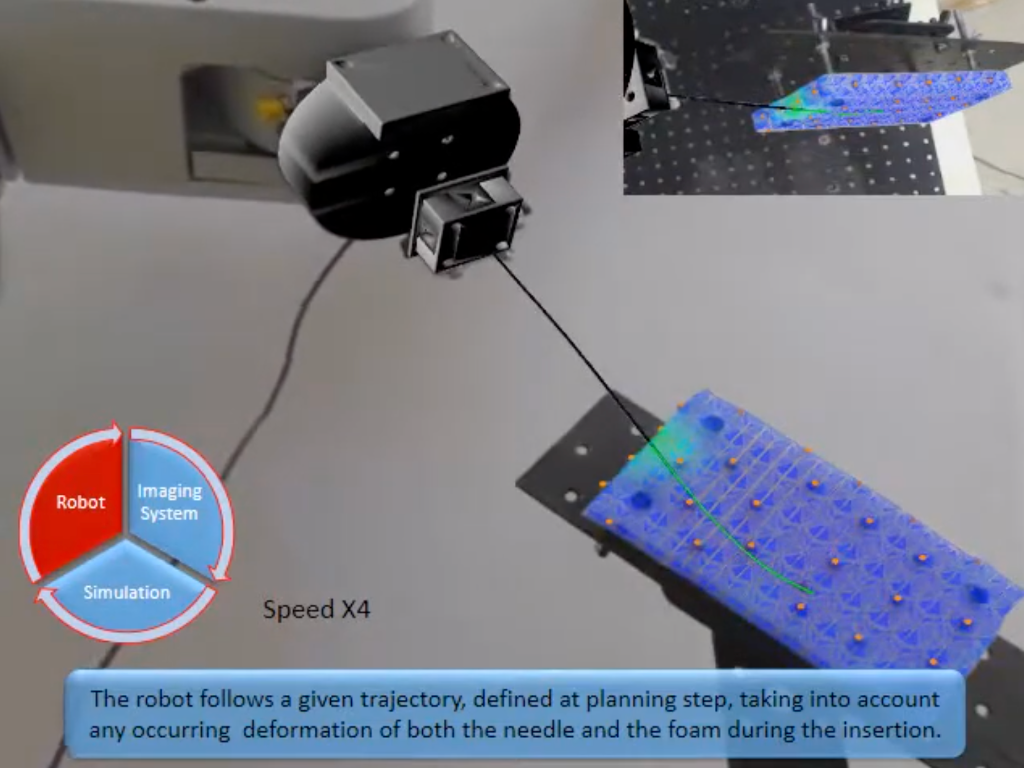
CONECT Project
Robotic Needle Insertion Guided by Real-time FEM Simulation
My PhD project at ICube (University of Strasbourg): robotic insertion of flexible needles in deformable tissue using inverse real-time finite element simulation, and augmented reality for surgery.