COSSEROOTS Project
Cosserat Theory for Soft Robotics Control
Research project applying Cosserat rod theory to the modeling and control of slender, continuum soft robots.
Project Overview
COSSEROOTS (2021–2022) studied control strategies for continuum soft robots using Cosserat rod theory. Slender robots — catheters, continuum arms, cable-driven structures — undergo large deformations that classical rigid-body models cannot capture; Cosserat models describe them with few degrees of freedom while staying accurate enough for control.
Cosserat Modeling
Reduced-coordinate rod models for large deformations of slender robots.
FEM Coupling
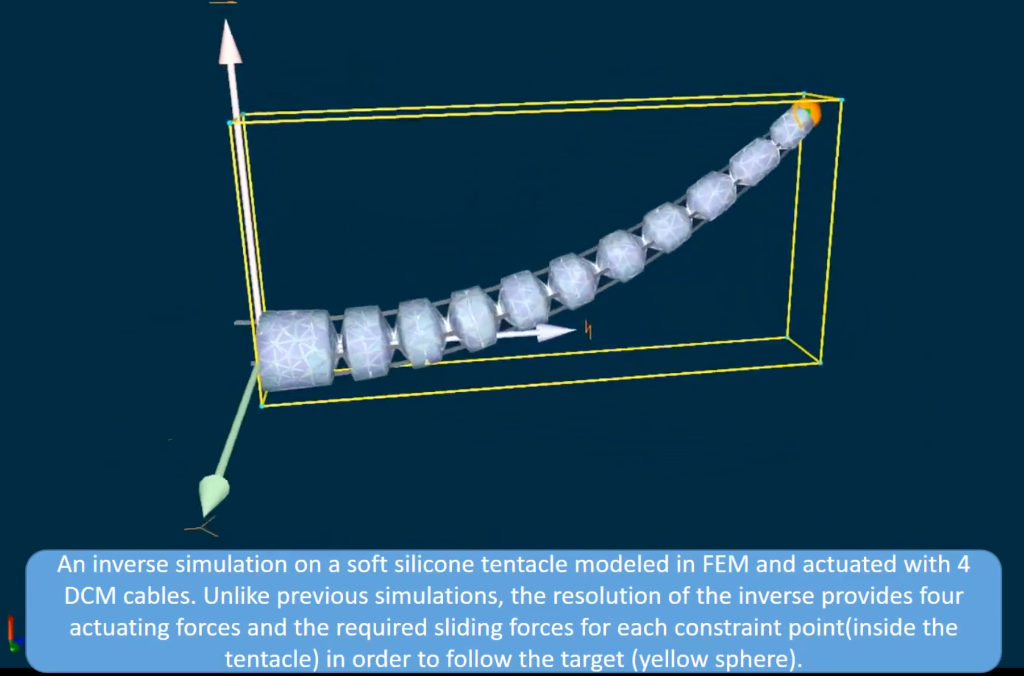
Coupling Cosserat rods (reduced coordinates) with FEM models (global coordinates) for direct and inverse kinematics.
Inverse Control
Computing the actuator inputs that achieve a desired shape or trajectory.
Software: the Cosserat Plugin for SOFA
The models developed in this line of work are available in the open-source Cosserat plugin for SOFA (C++ / Python), of which I am the lead developer. It is used by the soft robotics community to simulate rods, cables and continuum robots in real time.
Publications
- Coupling Numerical Deformable Models in Global and Reduced Coordinates for the Simulation of the Direct and the Inverse Kinematics of Soft Robots (2021) — Yinoussa Adagolodjo, Federico Renda, Christian Duriez. IEEE Robotics and Automation Letters. HAL · DOI
Contact me for more information about this project.